Consistent results thanks to controlled gripping force
Mechatronic gripping modules with sensorless gripping force control
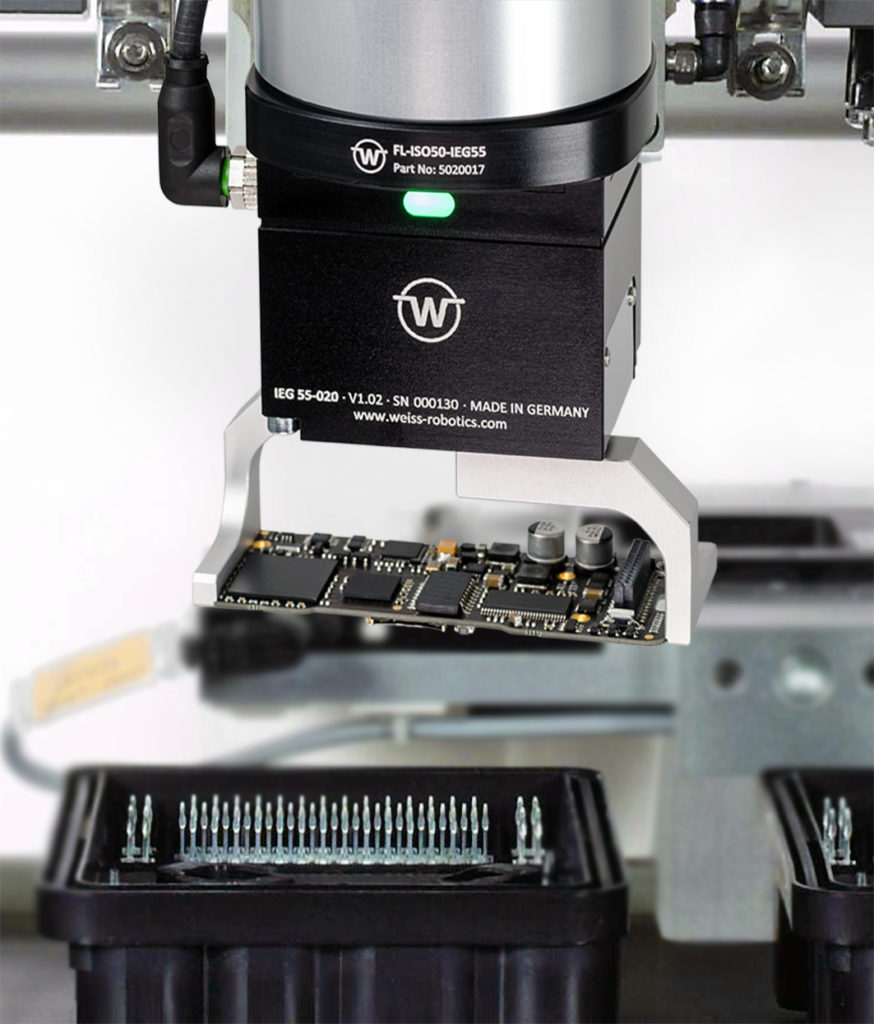
Unlike pneumatic gripping modules, electric gripping modules allow the gripping force to be better adapted to the object being handled. Conventional electric grippers often use simple current control of the drive motor for this purpose, which limits the winding current and thus the torque of the drive. However, adjusting the gripping force solely via the motor current has significant drawbacks. This is because, in order to set a specific gripping force, the user must take into account influencing factors such as gripping speed, lubrication condition, temperature, batch variation or ageing. Furthermore, a current limitation that is independent of movement has a negative effect on dynamics and, consequently, on the achievable cycle times.